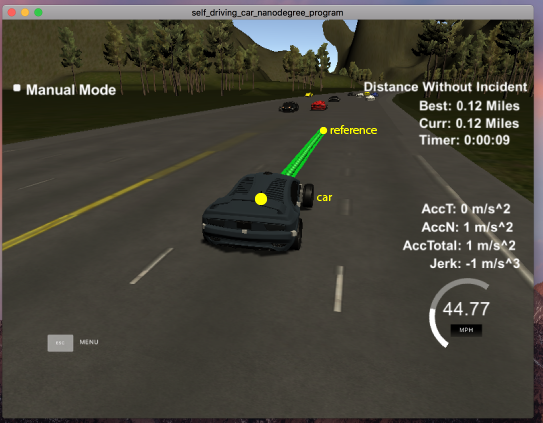
The aim of this project is to implement a car that drives automatically in a simulation world. The car should be able to switch the lane smoothly when necessary. I think this is the most fun and challenging project of Udacity Self-Driving Car Nanodegree.
The code repo and the explanation is here.